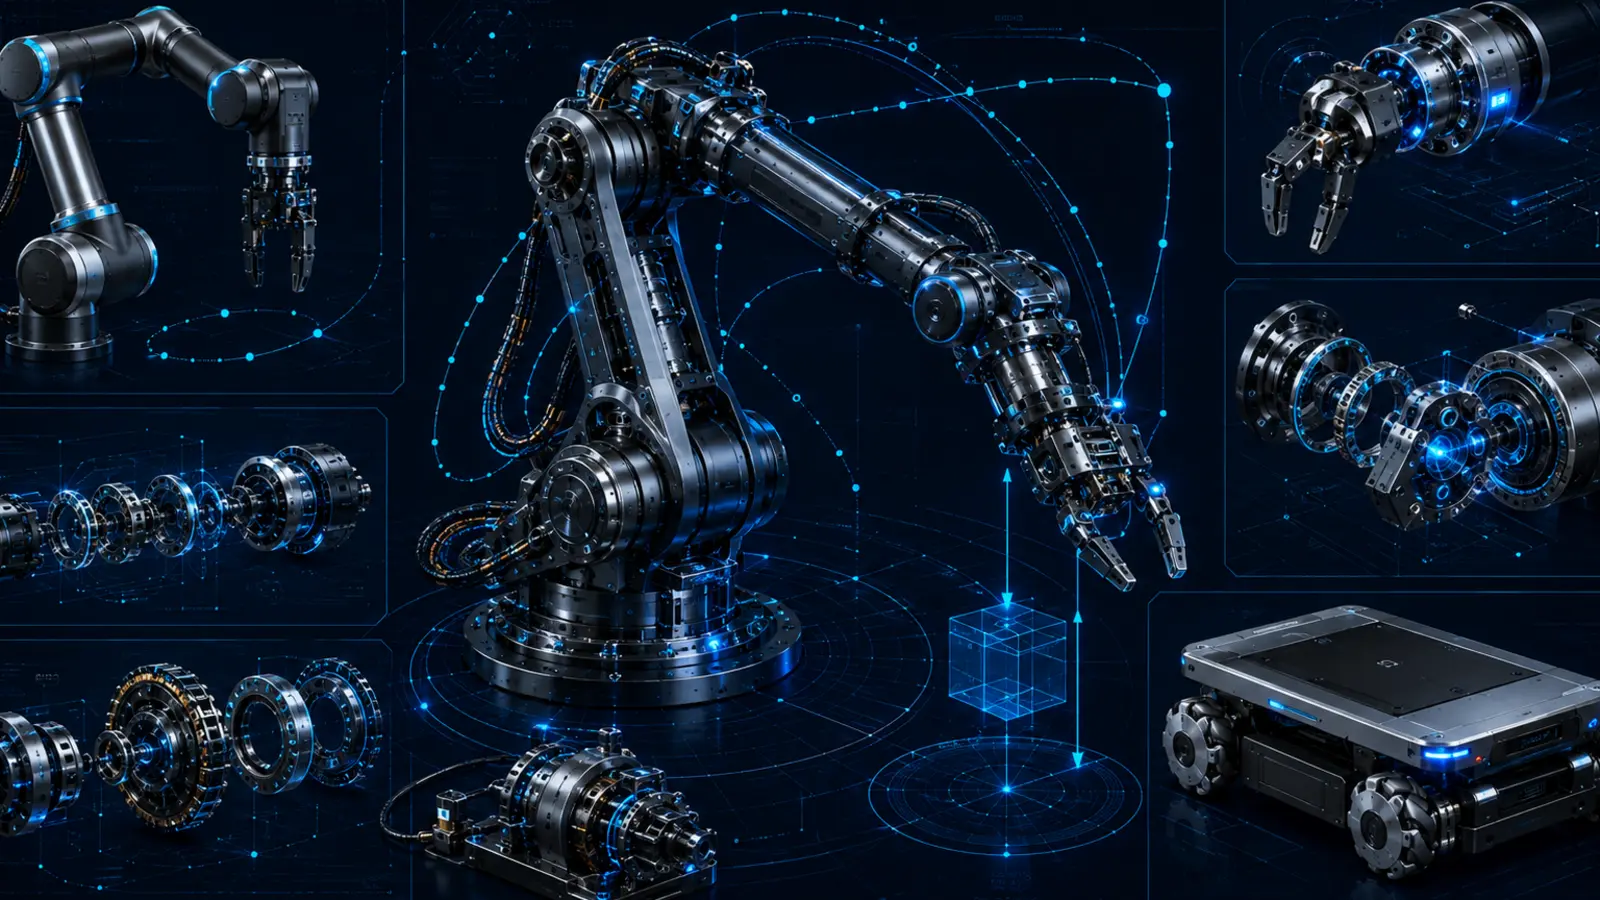
Articulated robots, collaborative machines, mobile platforms, kinematics, dynamics, trajectories, end effectors and load management.
Revision 1.9.1 · Phase 2 content and navigation review
Public-safe engineering gateway: this page explains responsibilities, interfaces, work products and review evidence without publishing application-specific dimensions, algorithms, allowables or unreleased performance data.
Engineering Role
Why This Gateway Exists
This gateway defines machines that place tools, sensors or payloads through controlled physical motion. It joins mechanism topology, kinematics, dynamics, end-effectors, perception and task planning into a realizable robotic system.
Questions This Team Must Close
What workspace, payload, reach and dexterity must the robot provide?
Which manipulator or mobile architecture best fits the task and environment?
How are singularities, collisions, loads and contact forces managed?
How will tooling, people and surrounding equipment interact with the robot?
Controlled Engineering Scope
Six Level-3 Topic Pages
Each daughter page defines a focused technical responsibility, the interfaces it must control and the evidence expected as the design matures.
Robotic behavior depends on mechanical geometry, actuator and drive limits, sensing, software planning, human interaction and safety supervision remaining consistent across every operating mode.