Mechatronics, Robotics & Motion Control
Mechatronics closes the loop between electrical power, sensing, computation and physical motion. Robotics extends that loop into coordinated mechanisms, perception, autonomy, human interaction and safety-controlled work.
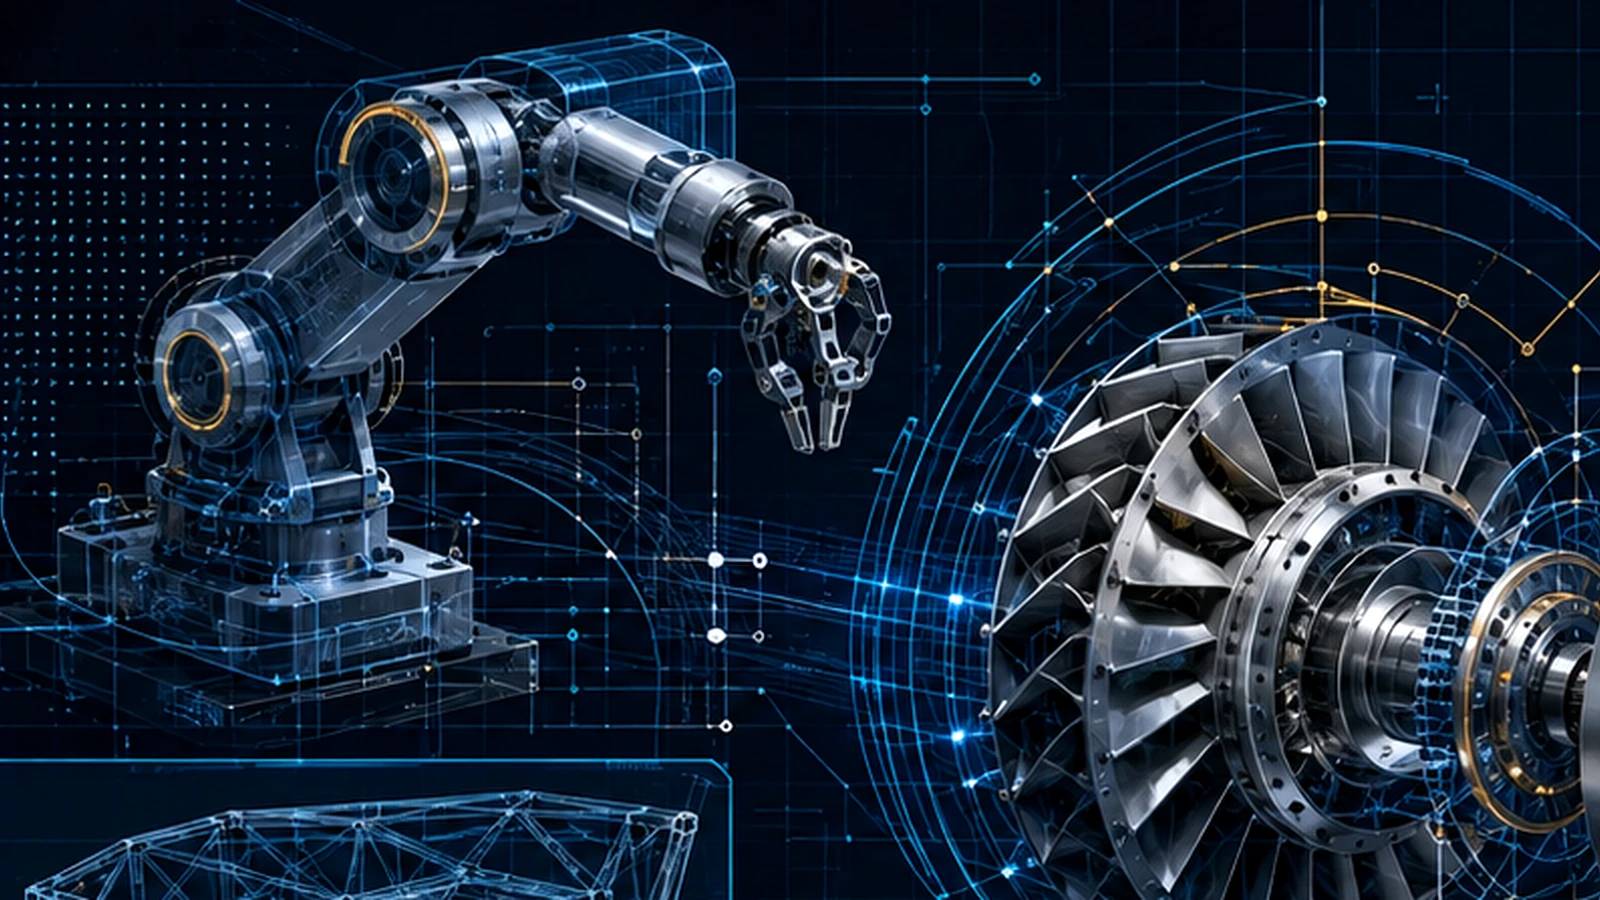
Sense, Decide, Actuate & Verify
A mechatronic system is not merely a motor attached to a controller. Performance emerges from the full loop and its physical, electrical, computational and safety constraints.
Measurement & State Estimation
Position, velocity, force, torque, current, pressure, temperature, vision and other feedback channels establish the system state and uncertainty.
Embedded & Real-Time Control
MCUs, DSPs, FPGAs, real-time software and safety logic execute deterministic control, coordination, fault response and bounded autonomy.
Motion, Force & Physical Work
Servo and stepper drives, electric motors, solenoids, brakes, clutches, hydraulic or pneumatic elements and compliant mechanisms convert commands into controlled work.
Primary Electrical Engineering Systems
These branches define the electrical hardware, interfaces and verification evidence required for robust mechatronic and robotic systems.
Motor Drives & Power Electronics
Power conversion, switching devices, gate drive, current control, regenerative energy, protection and thermal constraints.
Open system →
Sensors, Feedback & Instrumentation
Encoders, resolvers, inertial sensors, force/torque sensing, signal conditioning, calibration and diagnostic measurement.
Open system →
MCUs, DSPs, SoCs & Edge Compute
Real-time control, trajectory processing, machine vision, sensor fusion, edge inference and deterministic supervisory logic.
Open system →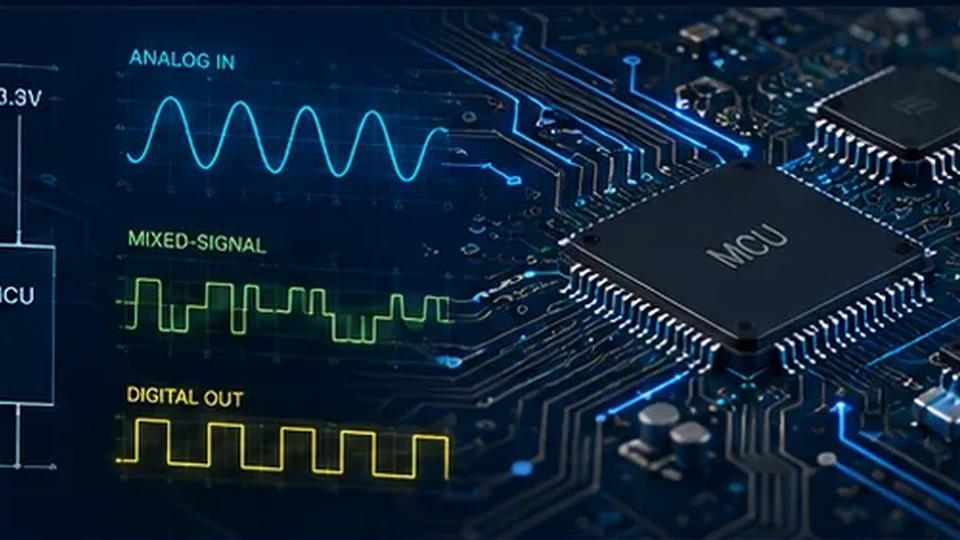
Analog & Mixed-Signal Interfaces
Sensor front ends, data conversion, references, filtering, timing and the analog/digital boundary around the control loop.
Open system →
Harnesses, Connectors & Networks
Moving cables, flex circuits, connector retention, shielding, industrial networks, service loops and maintainable interconnect.
Open system →
EMC, Grounding & Control Integrity
Motor-noise containment, return paths, grounding, emissions, immunity, ESD and resilient communications near switching power.
Open system →Robotics Spans Multiple Divisions
Electrical owns the control and power hardware; Mechanical owns structures, joints, actuators, transmissions and end effectors; Software/AI owns real-time behavior, perception, planning and bounded autonomy. Prototyping and validation close the loop with measured evidence.